General specifications
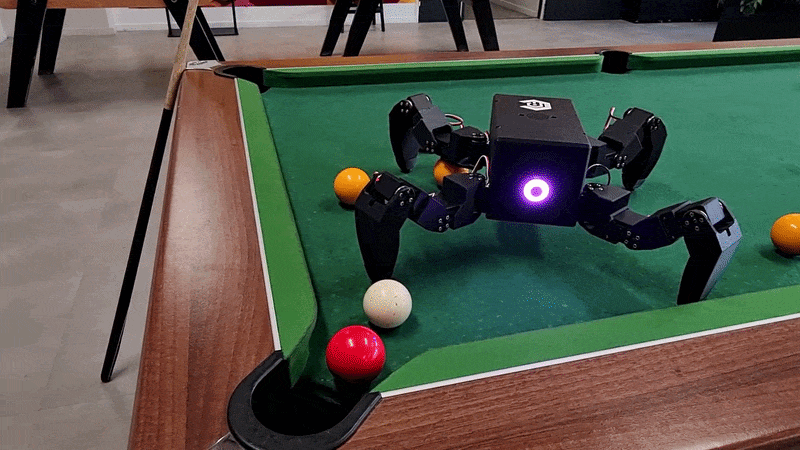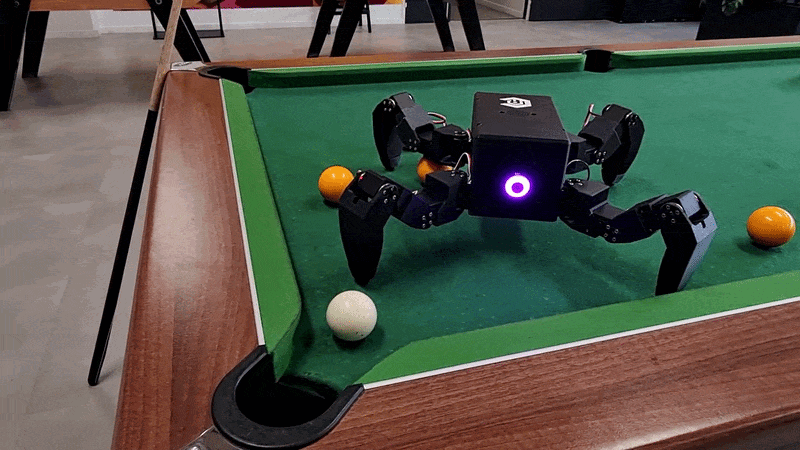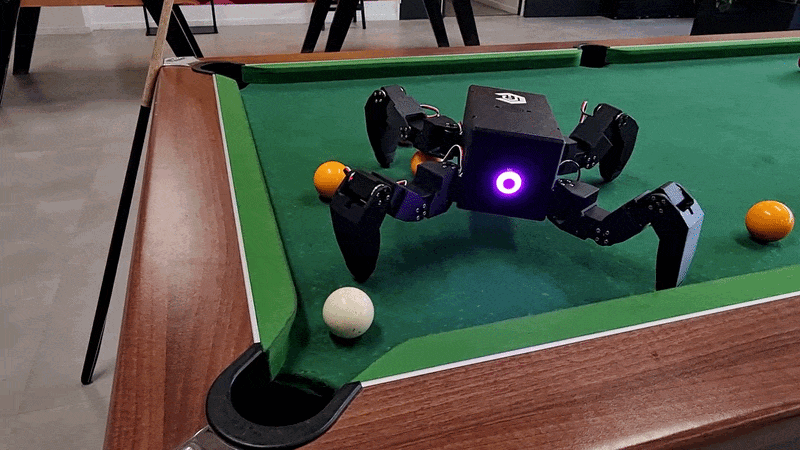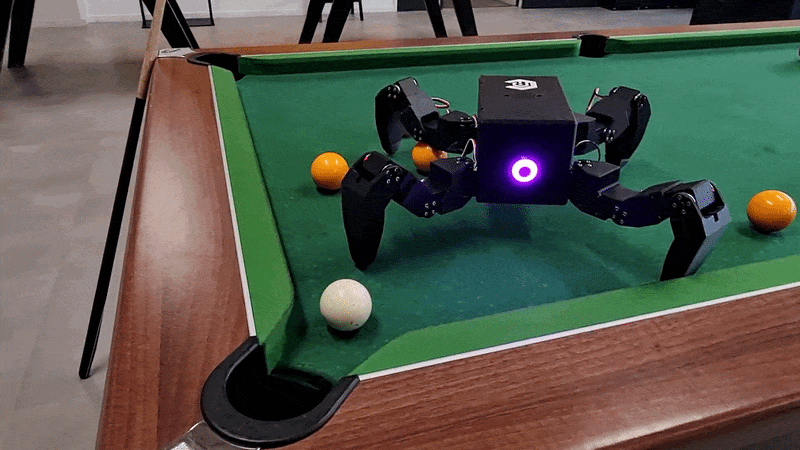
Key features
- 12-DoF quadruped robot: 4 legs with 3 DoF each
- 12 Feetech STS3215 serial servomotors on a single 1 Mbps bus
- Custom motherboard dedicated to real-time tasks: motor control, IMU and power management
- Onboard Raspberry Pi 4 for high-level control, vision and audio
- 2S 18650 battery, rechargeable over USB-C directly on the robot
- IMU, wide-angle camera and microphone for perception
- Speaker and 18-LED RGB ring for expressiveness
- Fully 3D-printable structure (PLA & TPU), weighing about 1.5 kg
- 100% open source: hardware, firmware and software
Dimensions and weight
| Property | Value |
|---|---|
| Standing dimensions (L × W × H) | ≈ 40 × 35 × 15 cm |
| Total weight | ≈ 1.5 kg |
| Coxa segment length | 69 mm |
| Femur segment length | 68 mm |
| Tibia segment length | 112 mm |
Note
These values are computed from the simulation model (URDF/MJCF) and from the CAD. They may differ slightly on the real robot depending on print settings and wiring.
Compute
Chromapi splits control between two boards, linked by a custom UART bridge protocol at 2 Mbps:
| Board | Role |
|---|---|
| STM32G431KBT6 (Arm Cortex-M4, custom motherboard) | Real-time tasks: servomotor control, IMU fusion, power monitoring, LED ring |
| Raspberry Pi 4 Model B | High-level control, locomotion, Python SDK, audio and vision |
Software
| Components | Repository |
|---|---|
| Control framework, kinematics, locomotion and simulation models | chromapi |
| Motherboard firmware and PCB design | chromapi_motherboard |